What is included?
One STT 1S MAX aircraft, one STT-HUB1101 cabinet, four aircraft batteries, and one STTBOT-S1 or STTBOT-T1.
SKYHUB
Catalogue specification Rev 1.3, 2026-09-27.
Download the English Rev 1.3 product manual (PDF)English customer edition, Rev 1.3, 27 September 2026.
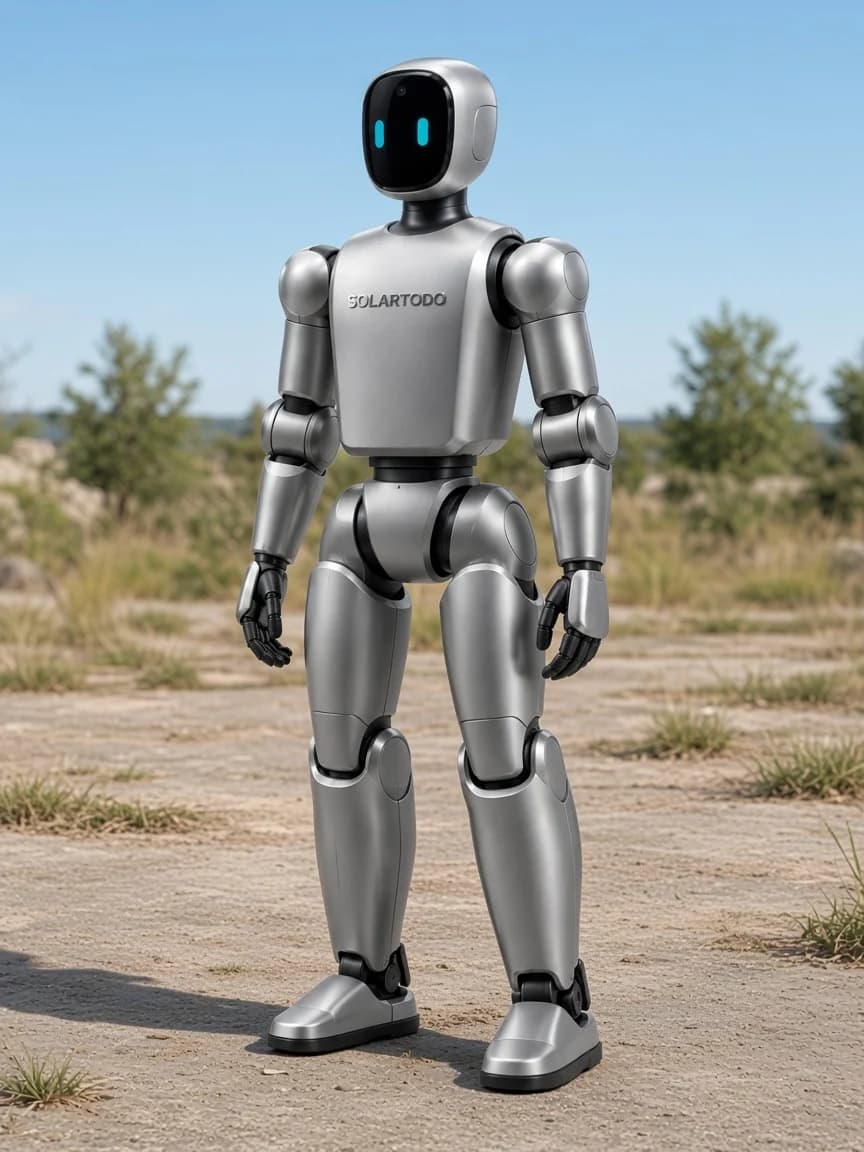
Same form as STTBOT-T1. S1 is the smaller size: approximately 880 mm, approximately 13 kg.
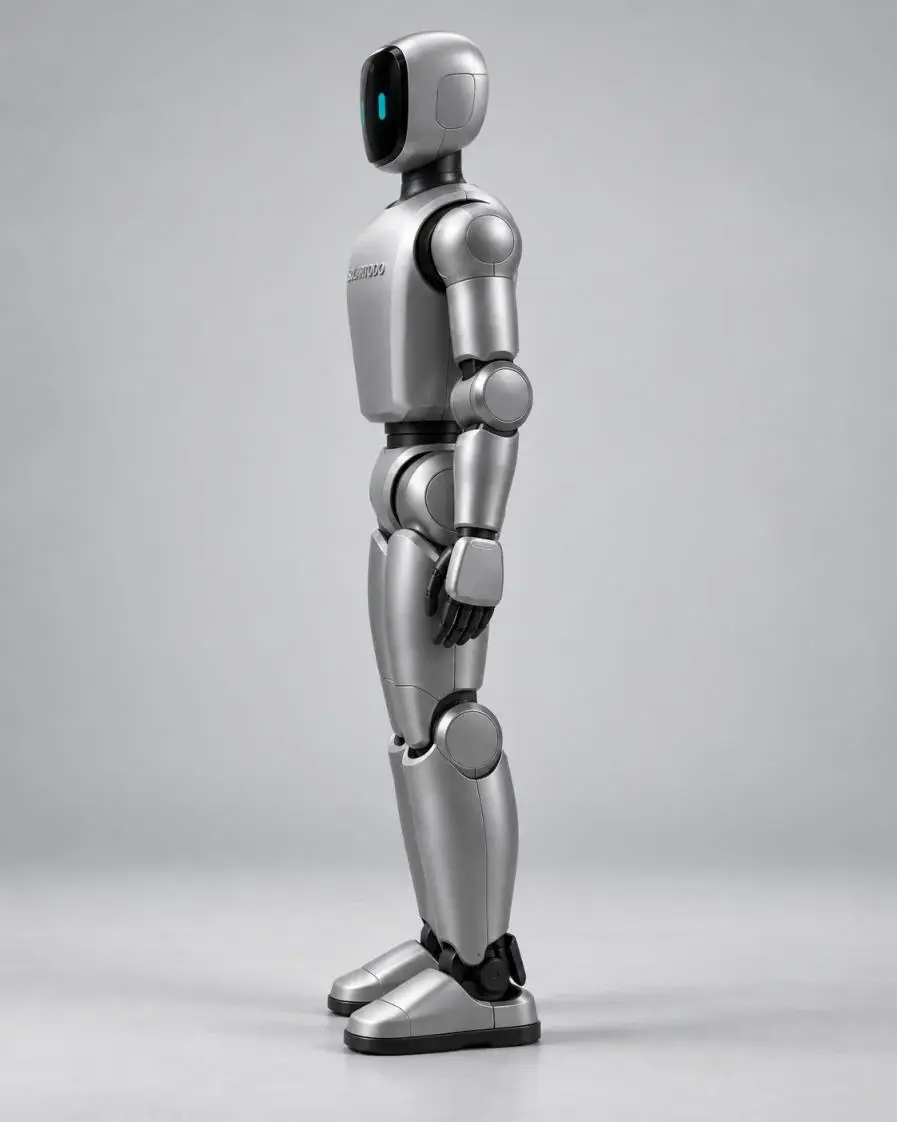
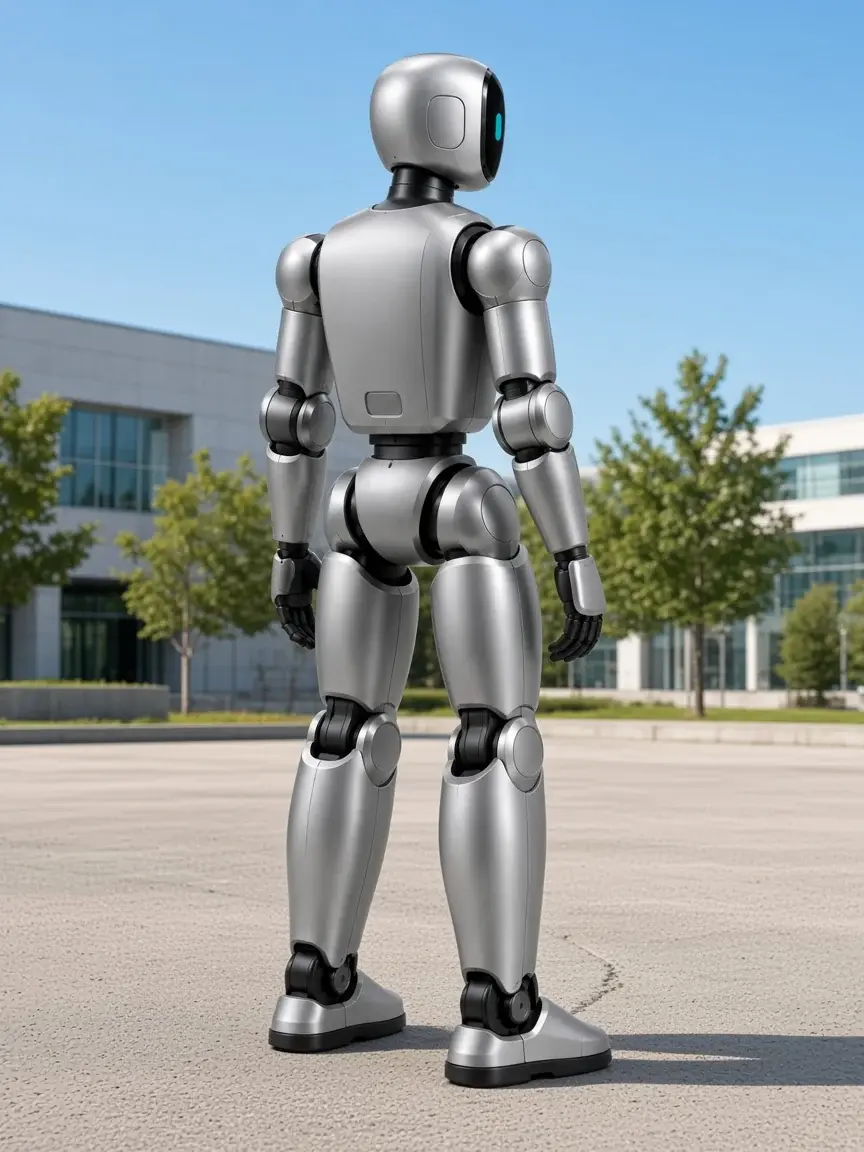
Standing height: approximately 880 mm
Condition text is the Rev 1.3 English catalogue wording.
| Specification | Value | Condition |
|---|---|---|
| Standing height | approximately 880 mm | |
| Mass | approximately 13 kg | |
| Degrees of freedom | 21 | legs 12, arms 8, waist 1 |
| Single-arm payload | approximately 2 kg | Arm payload, arm span, and shoulder width are not the same definition on S1 and T1 and must not be compared directly. |
| End effector | two-finger | |
| Battery voltage | 48 V | |
| Shoulder-frame inner distance | 130 mm | shoulder-frame inner distance only; not standing width or depth |
| Wireless charge power | 200 W | contactless module; 200 W is the transfer rating |
| Leg degrees of freedom | 6 per leg | |
| Arm degrees of freedom | 4 per arm | |
| Waist degrees of freedom | 1 yaw | |
| Arm reach description | 300–400 mm effective reach, including two-finger end effector | not the same measurement definition as the T1 arm span |
| Locomotion | Bipedal walking | |
| Onboard AI compute | 16 GB edge AI compute platform; up to 157 sparse INT8 TOPS / 78 dense INT8 TOPS module peak capability | Compute figures state processing capacity, not a measured site recognition accuracy or response latency. |
| Stereo depth sensing | Active-infrared stereo depth with 0.10 m to beyond 20 m module range; recommended working range approximately 0.26–3 m | Extreme sensor range is not a promised robot obstacle-recognition or object-identification distance. |
| Depth image | Up to 1280 × 800 at 30 frames/s | |
| RGB image | Up to 1920 × 1080 at 30 frames/s | |
| Depth field of view | Approximately 90° horizontal × 65° vertical | |
| RGB field of view | Approximately 86° horizontal × 55° vertical at 16:9 | |
| Inertial sensing | Six-axis IMU within the depth assembly; robot motion state also uses its joint and balance feedback | |
| 3D range sensing | 360° horizontal view; approximately −7° to +52° vertical view | |
| 3D range | Approximately 40 m on a 10% reflectivity target; 100 m maximum module range | 100 m cutoff is not a guaranteed detection distance. |
| Point output | Up to 200,000 points/s first return; typical 10 Hz point-cloud frame rate | |
| Laser product classification | Class 1 at 905 nm for the specified range-sensing assembly | |
| Wireless link | Wi-Fi 6 and Bluetooth 5.2 | |
| Wired/service link | Ethernet and USB with controller-specific expansion | |
| Single-arm working description | Approximately 300–400 mm effective extension, including the two-finger end effector | not a like-for-like reach comparison with the T1 arm span |
| Base movement | Bipedal walking, standing, squatting and configured dynamic motions | |
| Coupling | Near-field magnetic inductive / resonant transfer | |
| Suggested operating gap | 5–15 mm; preferred 8–10 mm | |
| Lateral alignment | Approximately ±10 mm | subject to dock geometry |
| Transfer efficiency | At least 85% at specified alignment; typical 88–90% in favorable alignment | |
| Receiver output | Configurable 48–54.6 V DC, maximum 200 W | 200 W is the contactless transfer rating, not a full-charge time and not the approximately 2 h working time. |
| Charge control | BMS-linked start/stop and monitored constant-current/constant-voltage profile | |
| Protective functions | Input/output voltage, overcurrent, short circuit, overtemperature, undervoltage and foreign-object detection |
Arm payload, arm span, and shoulder width are not the same definition on S1 and T1 and must not be compared directly. S1 joint angles must not be copied from T1.
One STT 1S MAX aircraft, one STT-HUB1101 cabinet, four aircraft batteries, and one STTBOT-S1 or STTBOT-T1.
STTBOT-S1 is approximately 880 mm and approximately 13 kg. STTBOT-T1 is 1,320 mm and approximately 35 kg. They are sold separately.
On its own 200 W wireless position. It does not enter the hangar battery bay. 200 W is not a full-charge time.
No. 54 min is the maximum forward flight time at 12 m/s, no wind, photo mode, obstacle action off, 100% to 0% SOC. Maximum flight time is not a guaranteed route duration.
No. It is not a street-light pole and it does not mount on a pole. The octagonal silicon pole and the cylindrical CIGS pole are two other products in this catalogue.